A magnetic encoder is a precision measurement device that converts angular or linear mechanical displacement into electrical signals using magnetic field sensing. Widely used in industrial automation, robotics, automotive systems, and consumer electronics, magnetic encoders are known for their durability, resistance to harsh environments, and high reliability. Understanding the magnetic encoder principle helps engineers and technicians select the right sensor technology for motion control applications where performance, longevity, and cost-effectiveness are critical.
Unlike optical encoders that rely on light transmission through slotted disks, magnetic encoders operate based on the Hall effect or magnetoresistive principles, making them immune to dust, oil, moisture, and vibration. This unique operating mechanism has made magnetic encoders the preferred choice in environments where optical sensors would fail quickly.
How Does a Magnetic Encoder Work?
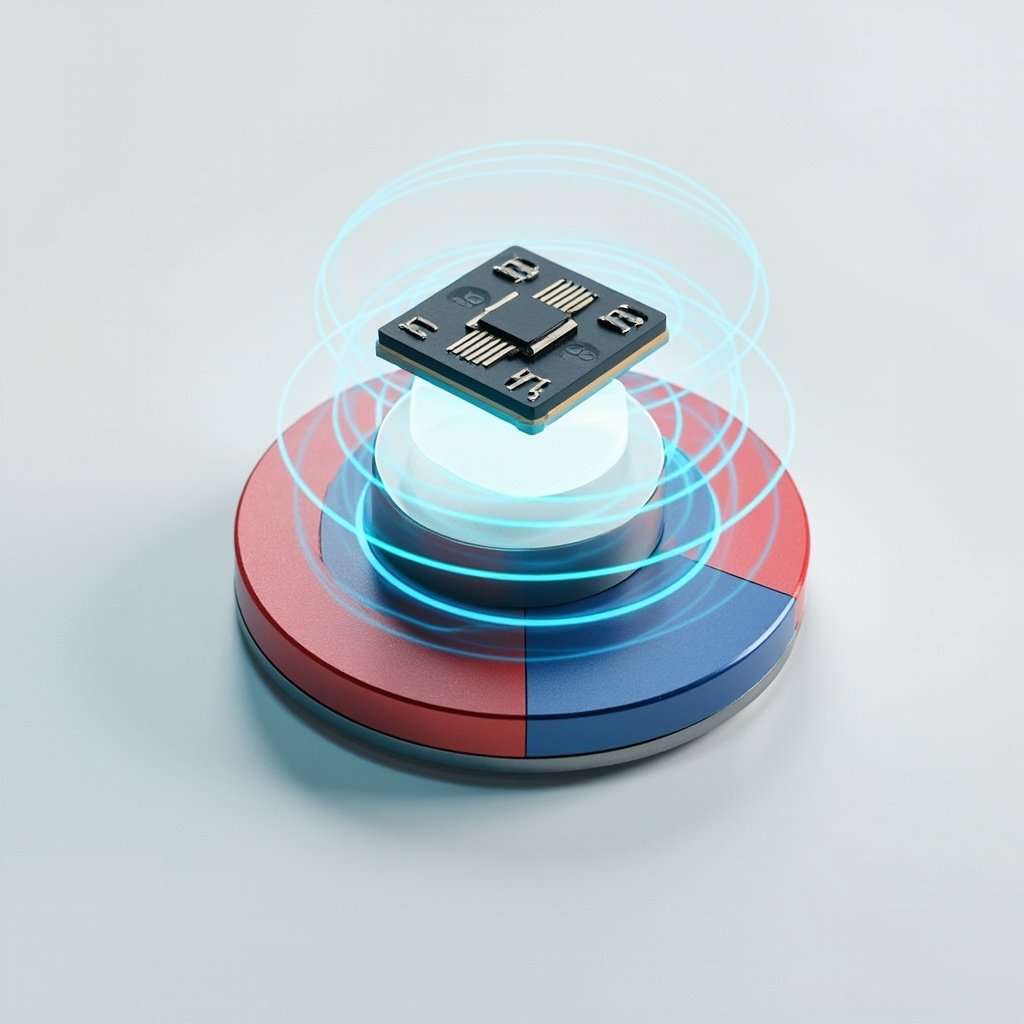
The fundamental working principle of a magnetic encoder is based on the detection of changes in a magnetic field as a magnetized component moves relative to a magnetic sensor. The encoder typically consists of two main parts: a magnetic scale or rotor and a sensor head. As the rotor spins or moves linearly, alternating north and south poles pass by the sensor, generating a sinusoidal or digital output signal proportional to position.
Key Components of a Magnetic Encoder
- Magnetic Scale/Rotor: A disk or strip with alternating magnetic poles (north and south) magnetized at precise intervals, typically 1 mm to 5 mm pitch.
- Sensor Head: Contains Hall effect sensors, anisotropic magnetoresistive (AMR), giant magnetoresistive (GMR), or tunneling magnetoresistive (TMR) elements that detect magnetic field changes.
- Signal Processing Unit: An electronic circuit that converts raw sensor signals into standardized output formats such as incremental quadrature (A/B/Z), SSI, BiSS, or analog signals.
- Housing: A robust protective enclosure, often IP67-rated, that shields internal components from contaminants, mechanical shock, and temperature fluctuations.
- Bearings and Shaft: High-precision mechanical components ensuring smooth, accurate rotation with minimal runout and friction.
The Hall Effect and Magnetoresistive Principles
The two most common physical principles used in magnetic encoders are the Hall effect and magnetoresistance. The Hall effect, discovered by Edwin Hall in 1879, occurs when a current-carrying conductor placed in a magnetic field generates a voltage perpendicular to both the current and the field. Modern Hall sensors use semiconductor materials that produce measurable voltage changes when exposed to varying magnetic flux densities.
Magnetoresistive sensors, on the other hand, change their electrical resistance in response to magnetic fields. AMR sensors offer higher sensitivity, while GMR and TMR sensors provide even greater accuracy and temperature stability, enabling resolutions down to sub-micron levels in advanced applications.
Types of Magnetic Encoders
Magnetic encoders are generally classified into two main categories based on their output type and measurement approach. Each type serves different application requirements and offers distinct advantages.
1. Incremental Magnetic Encoders
Incremental encoders produce a series of pulses as the shaft rotates, providing relative position information. They typically generate two square wave outputs (channels A and B) that are 90 degrees out of phase, plus an optional index pulse (channel Z) for one-revolution reference. Position is determined by counting pulses from a known starting point.
2. Absolute Magnetic Encoders
Absolute encoders provide a unique digital code for every position within a full revolution, retaining positional information even after power loss. They use multi-track magnetic patterns or sophisticated algorithms to deliver high-resolution absolute position feedback, often through serial protocols like SSI, BiSS, or CANopen.
⚠️ Engineering Tip: When selecting a magnetic encoder, always consider the air gap tolerance between the magnetic scale and sensor head. Typical industrial-grade encoders allow 0.5–3.0 mm gap variation, but excessive misalignment can cause signal degradation, count errors, or complete signal loss. Always follow manufacturer mounting guidelines to ensure optimal performance.
Magnetic Encoder vs. Optical Encoder Comparison
Choosing between magnetic and optical encoders depends on application requirements. The table below summarizes key differences to help you make an informed decision.
| Parameter | Magnetic Encoder | Optical Encoder |
|---|---|---|
| Resolution | Up to 20+ bit absolute | Up to 25+ bit absolute |
| Environmental Resistance | Excellent (dust, oil, water) | Poor (sensitive to contamination) |
| Operating Temperature | -40°C to +125°C typical | -20°C to +85°C typical |
| Shock/Vibration Tolerance | Very High | Moderate |
| Cost | Low to Medium | Medium to High |
| Typical Lifespan | Long (no contact wear) | Medium (LED degradation) |
Key Advantages of Magnetic Encoders
- High Durability: No optical components means no exposure to dust, dirt, oil, or condensation, making them ideal for harsh industrial environments.
- Wide Temperature Range: Operate reliably across extreme temperatures, suitable for outdoor, automotive, and aerospace applications.
- Resistance to Shock and Vibration: Solid-state sensing technology withstands mechanical impacts better than fragile optical disks.
- Long Service Life: Contactless operation eliminates mechanical wear, often exceeding 100,000 hours of operation.
- Cost-Effective: Simpler construction and lower component count translate to competitive pricing for many applications.
- Compact Size: Available in miniature form factors, perfect for space-constrained applications like small motors and robotics.
Common Applications of Magnetic Encoders
Magnetic encoders are used in an incredibly diverse range of industries and applications. Their robustness and reliability make them indispensable in scenarios where other encoder technologies would fail.
- Servo Motors and Stepper Motors: Provide closed-loop position feedback for precise motion control in CNC machines, robotics, and automation systems.
- Automotive Systems: Used in throttle position sensing, steering angle measurement, transmission control, and electric vehicle traction motors.
- Industrial Automation: Position feedback in conveyor systems, packaging machinery, and assembly line equipment.
- Renewable Energy: Wind turbine pitch and yaw control, solar tracker positioning systems.
- Medical Equipment: MRI machines, surgical robots, and infusion pumps requiring reliable, non-magnetic-interference-free position sensing.
- Aerospace and Defense: Flight control surfaces, landing gear systems, and satellite antenna positioning.
- Consumer Electronics: Camera autofocus mechanisms, printer head positioning, and home appliance motor control.
Limitations and Considerations
Despite their many benefits, magnetic encoders do have certain limitations that engineers must consider during system design. Understanding these constraints ensures successful integration and long-term reliability.
- Lower Resolution Than Optical: Although modern TMR-based encoders achieve high resolutions, optical encoders still lead in ultra-high-precision applications requiring sub-arcsecond accuracy.
- Magnetic Interference: External magnetic fields from motors, transformers, or permanent magnets can disrupt readings if proper shielding is not implemented.
- Air Gap Sensitivity: Signal quality depends on maintaining proper distance between sensor and magnetic scale, requiring careful mechanical design.
- Signal Jitter: Magnetic signals inherently contain more noise than optical signals, sometimes requiring additional filtering for ultra-precise applications.
Future Trends in Magnetic Encoder Technology
The magnetic encoder market continues to evolve rapidly, driven by advances in semiconductor technology and growing demand from automation, electric vehicles, and IoT applications. Emerging trends include the development of